Yutong Wang

Yutong Wang汪禹同

MSR student, Robotics Institute · Carnegie Mellon University

I work on making aerial robots reliable when they physically interact with the world.

I am a Master of Science in Robotics student at the CMU Robotics Institute, co-advised by Guanya Shi and Sebastian Scherer across the LeCAR Lab and the AirLab. My research runs from multi-robot motion planning under connectivity and safety constraints to learning-based control for aerial manipulation.

Before CMU I was at Brown University, where I earned an Sc.B. in Computer Science (Honors, magna cum laude) and an A.B. in International and Public Affairs, and worked with Nora Ayanian on trajectory planning for large robot swarms. Earlier I built autonomous-driving perception data infrastructure at Horizon Robotics.

nowCross-embodiment mobile manipulation.

01

News

02

Publications

Yutong Wang, Dongjae Lee, Xiaofeng Guo, Yuanzhu Zhan, Yufei Jiang, Bavin Saravanan, Muqing Cao, Jia Xie, Chenyang Mao, Sebastian Scherer, Junyi Geng, Guanya Shi

Conference on Robot Learning (CoRL) 2026

12 aerial manipulation tasks across underactuated, fully actuated, and overactuated robots — so you can tell whether the embodiment, the controller, or the policy is what failed.
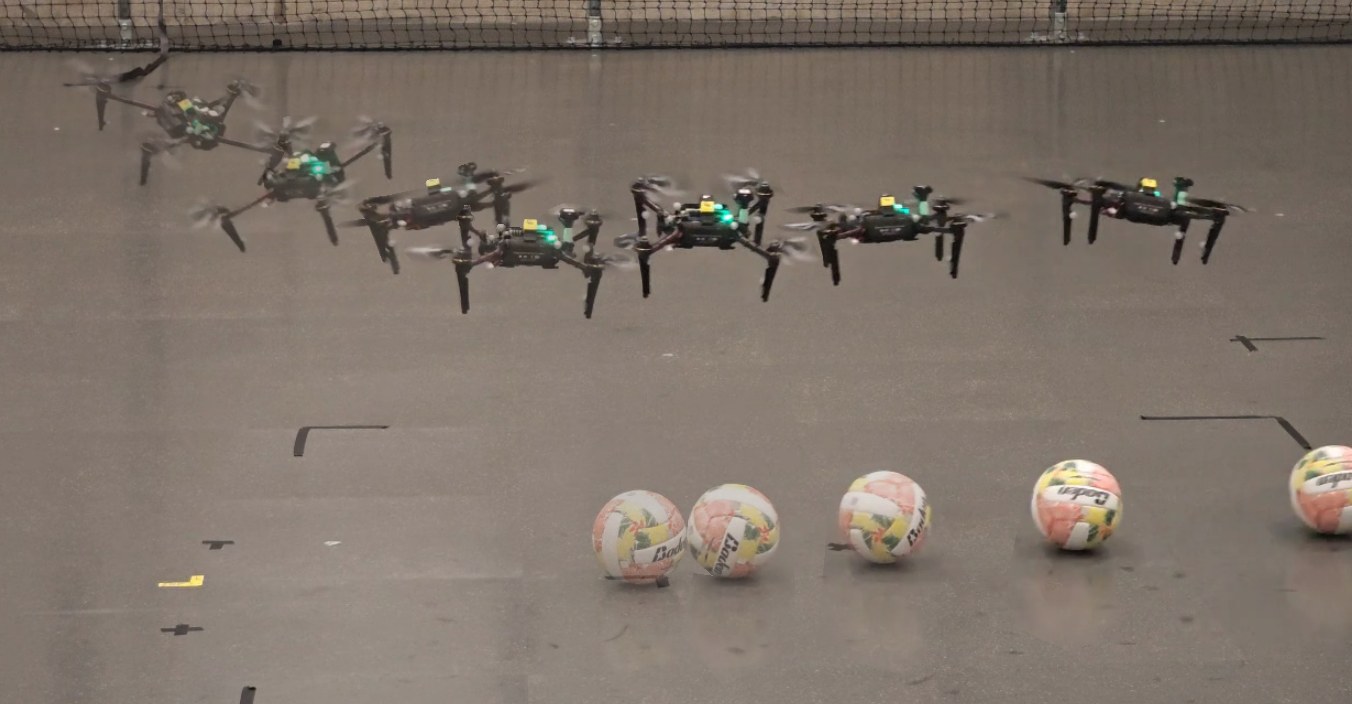
Composite of a quadrotor flying over a row of volleyballs, which it pushes along the floor with its propeller downwash.

Neelay Joglekar, Bavin Saravanan, Yutong Wang, Varun Kandiyappan, Junyi Geng, Sebastian Scherer

IROS 2026 Workshop on Sim2Real and Classical Control 2026

Best Methodology Paper Award

Instead of treating a multicopter's downwash as a disturbance, use it as a manipulation tool: an RL policy trained on a simplified downwash model dribbles a ball and transfers to the real world.

arXiv